
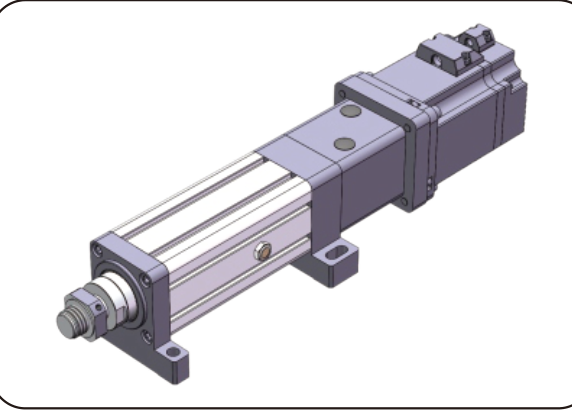
EDA140 · 전동 실린더와 리니어 액추에이터
전동 실린더는 안내된 확장 운동을 제공합니다. 추력, 스트로크, 속도, 작업 주기, 하중 연결을 하나의 조립체 요구로 정리합니다.
EDA140 비교
EDA140의 위치결정 정밀도 | 정밀도 등급, 볼 직경, 볼스크루 강성는 표시된 파라미터 그룹과 변형별로 확인하세요. 해당 스크루와 연결 도면을 비교합니다. 추력, 확장량, 속도를 함께 확인하며 개별 최대값만으로 운전점을 정하지 않습니다.
매개변수와 적용 범위
| 위치결정 정밀도 | 정밀도 등급 원본 조건; 아직 구조화되지 않음 · (Note: The parameters of the ball screw are applicable to strokes ≤ 300mm. For strokes greater than 300mm, please consult our technical personnel.) · 현재 기술 모델 · Ball screw parameters; Source row: JFZ5010-8; Source column: Accuracy Positioning | accuracy level | C5/±0.01 |
|---|---|
| 위치결정 정밀도 | 정밀도 등급 원본 조건; 아직 구조화되지 않음 · (Note: The parameters of the ball screw are applicable to strokes ≤ 300mm. For strokes greater than 300mm, please consult our technical personnel.) · 현재 기술 모델 · Ball screw parameters; Source row: JFZ5010-8; Source column: Accuracy Positioning | accuracy level | C7/±0.02 |
| 볼 직경 원본 조건; 아직 구조화되지 않음 · (Note: The parameters of the ball screw are applicable to strokes ≤ 300mm. For strokes greater than 300mm, please consult our technical personnel.) · 현재 기술 모델 · Ball screw parameters; Source row: JFZ5010-8; Source column: Ball diameter | 7.144mm mm |
| 볼스크루 강성 원본 조건; 아직 구조화되지 않음 · (Note: The parameters of the ball screw are applicable to strokes ≤ 300mm. For strokes greater than 300mm, please consult our technical personnel.) · 현재 기술 모델 · Ball screw parameters; Source row: JFZ5010-8; Source column: Ball screw rigidity | / |
| 볼스크루 강성 원본 조건; 아직 구조화되지 않음 · (Note: The parameters of the ball screw are applicable to strokes ≤ 300mm. For strokes greater than 300mm, please consult our technical personnel.) · 현재 기술 모델 · Ball screw parameters; Source row: SFU5010-8; Source column: Ball screw rigidity | / |
| 볼스크루 강성 원본 조건; 아직 구조화되지 않음 · (Note: The parameters of the ball screw are applicable to strokes ≤ 300mm. For strokes greater than 300mm, please consult our technical personnel.) · 현재 기술 모델 · Ball screw parameters; Source row: JFZ5020-7; Source column: Ball screw rigidity | / |
| C 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: External thread; Source column: C | 70 |
| C 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Internal thread; Source column: C | 45 |
| C 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Type I connector; Source column: C | — |
| C 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Fisheye bearing; Source column: C | — |
| C 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Y-joint; Source column: C | — |
| Ca (KN) 원본 조건; 아직 구조화되지 않음 · (Note: The parameters of the ball screw are applicable to strokes ≤ 300mm. For strokes greater than 300mm, please consult our technical personnel.) · 현재 기술 모델 · Ball screw parameters; Source row: JFZ5010-8; Source column: Ca (KN) | 104.1 KN |
| Ca (KN) 원본 조건; 아직 구조화되지 않음 · (Note: The parameters of the ball screw are applicable to strokes ≤ 300mm. For strokes greater than 300mm, please consult our technical personnel.) · 현재 기술 모델 · Ball screw parameters; Source row: SFU5010-8; Source column: Ca (KN) | 104.1 KN |
| Ca (KN) 원본 조건; 아직 구조화되지 않음 · (Note: The parameters of the ball screw are applicable to strokes ≤ 300mm. For strokes greater than 300mm, please consult our technical personnel.) · 현재 기술 모델 · Ball screw parameters; Source row: JFZ5020-7; Source column: Ca (KN) | 955 KN |
| 동기 풀리 중심 거리 현재 기술 모델 · Synchronous wheel and synchronous belt:; Source row: 1:1; Source column: Center distance of synchronous wheel | 196mm mm |
| Coa (KN) 원본 조건; 아직 구조화되지 않음 · (Note: The parameters of the ball screw are applicable to strokes ≤ 300mm. For strokes greater than 300mm, please consult our technical personnel.) · 현재 기술 모델 · Ball screw parameters; Source row: JFZ5010-8; Source column: Coa (KN) | 251.2 KN |
| Coa (KN) 원본 조건; 아직 구조화되지 않음 · (Note: The parameters of the ball screw are applicable to strokes ≤ 300mm. For strokes greater than 300mm, please consult our technical personnel.) · 현재 기술 모델 · Ball screw parameters; Source row: SFU5010-8; Source column: Coa (KN) | 251.2 KN |
| Coa (KN) 원본 조건; 아직 구조화되지 않음 · (Note: The parameters of the ball screw are applicable to strokes ≤ 300mm. For strokes greater than 300mm, please consult our technical personnel.) · 현재 기술 모델 · Ball screw parameters; Source row: JFZ5020-7; Source column: Coa (KN) | 230.7 KN |
| Cor (KN) 현재 기술 모델 · Bearing parameters:; Source row: Deep groove ball 6009-ZZx2; Source column: Cor (KN) | 14 KN |
| Cor (KN) 현재 기술 모델 · Bearing parameters:; Source row: Flat thrust bearing 51212; Source column: Cor (KN) | 179 KN |
| Cr (KN) 현재 기술 모델 · Bearing parameters:; Source row: Deep groove ball 6009-ZZx2; Source column: Cr (KN) | 19.9 KN |
| Cr (KN) 현재 기술 모델 · Bearing parameters:; Source row: Flat thrust bearing 51212; Source column: Cr (KN) | 73.5 KN |
| D 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: External thread; Source column: D | 120 |
| D 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Internal thread; Source column: D | 50 |
| D 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Type I connector; Source column: D | 245 |
| D 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Fisheye bearing; Source column: D | 165 |
| D 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Y-joint; Source column: D | 245 |
| 직경 원본 조건; 아직 구조화되지 않음 · (Note: The parameters of the ball screw are applicable to strokes ≤ 300mm. For strokes greater than 300mm, please consult our technical personnel.) · 현재 기술 모델 · Ball screw parameters; Source row: JFZ5010-8; Source column: Diameter | 50 mm mm |
| 종동 기어 사양 현재 기술 모델 · Synchronous wheel and synchronous belt:; Source row: 1:1; Source column: Driven gear specifications | 14M65T77 T |
| 구동 기어 사양 현재 기술 모델 · Synchronous wheel and synchronous belt:; Source row: 1:1; Source column: Driving gear specifications | 14M65T77 T |
| E 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: External thread; Source column: E | 10 |
| E 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Internal thread; Source column: E | 10 |
| E 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Type I connector; Source column: E | 10 |
| E 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Fisheye bearing; Source column: E | 10 |
| E 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Y-joint; Source column: E | 10 |
| F 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: External thread; Source column: F | 14 |
| F 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Internal thread; Source column: F | — |
| F 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Type I connector; Source column: F | 40 |
| F 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Fisheye bearing; Source column: F | 60 |
| F 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Y-joint; Source column: F | 40.3 |
| G 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: External thread; Source column: G | — |
| G 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Internal thread; Source column: G | — |
| G 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Type I connector; Source column: G | — |
| G 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Fisheye bearing; Source column: G | — |
| G 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Y-joint; Source column: G | 85 |
| H 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: External thread; Source column: H | — |
| H 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Internal thread; Source column: H | — |
| H 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Type I connector; Source column: H | 85 |
| H 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Fisheye bearing; Source column: H | — |
| H 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Y-joint; Source column: H | 86 |
| 볼스크루 리드 원본 조건; 아직 구조화되지 않음 · (Note: The parameters of the ball screw are applicable to strokes ≤ 300mm. For strokes greater than 300mm, please consult our technical personnel.) · 현재 기술 모델 · Ball screw parameters; Source row: JFZ5010-8; Source column: Lead of ball screw | 10mm mm |
| 볼스크루 리드 원본 조건; 아직 구조화되지 않음 · (Note: The parameters of the ball screw are applicable to strokes ≤ 300mm. For strokes greater than 300mm, please consult our technical personnel.) · 현재 기술 모델 · Ball screw parameters; Source row: JFZ5020-7; Source column: Lead of ball screw | 20mm mm |
| 리미트 스위치 원본 조건; 아직 구조화되지 않음 · (Note: Thrust, stroke, and speed should be combined with actual usage, and the upper limit values of the three cannot be used together.) · 현재 기술 모델 · Basic parameters:; Source row: φ132 mm; Source column: Limit switch | Proximity switch |
| M 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: External thread; Source column: M | M50x2 |
| M 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Internal thread; Source column: M | M30x1.5 |
| M 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Type I connector; Source column: M | — |
| M 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Fisheye bearing; Source column: M | — |
| M 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Y-joint; Source column: M | — |
| 최대 허용 속도 원본 조건; 아직 구조화되지 않음 · (Note: Thrust, stroke, and speed should be combined with actual usage, and the upper limit values of the three cannot be used together.) · 현재 기술 모델 · Basic parameters:; Source row: φ132 mm; Source column: Maximum allowed speed Rotation angle of piston rod | ≤250 mm/s mm/s |
| 최대 허용 추력 원본 조건; 아직 구조화되지 않음 · (Note: Thrust, stroke, and speed should be combined with actual usage, and the upper limit values of the three cannot be used together.) · 현재 기술 모델 · Basic parameters:; Source row: φ132 mm; Source column: Maximum thrust allowed | ≤130KN KN |
| 직접 장착 가능한 모터 사양 현재 기술 모델 · Optional configuration:; Source row: 10mm; Source column: Motor specifications that can be directly installed | NO |
| 구동 기어 잇수 현재 기술 모델 · Synchronous wheel and synchronous belt:; Source row: 1:1; Source column: Number of active gear teeth | 28 |
| 종동 휠 잇수 현재 기술 모델 · Synchronous wheel and synchronous belt:; Source row: 1:1; Source column: Number of driven wheel teeth | 28 |
| 조합 가능한 감속기 현재 기술 모델 · Optional configuration:; Source row: 10mm; Source column: Reducers that can be matched | 142A |
| 조합 가능한 감속기 현재 기술 모델 · Optional configuration:; Source row: 10mm; Source column: Reducers that can be matched | 130A、180A |
| 피스톤 로드 회전각 원본 조건; 아직 구조화되지 않음 · (Note: Thrust, stroke, and speed should be combined with actual usage, and the upper limit values of the three cannot be used together.) · 현재 기술 모델 · Basic parameters:; Source row: φ132 mm; Source column: | ±0.3° ° |
| Scalable length 원본 조건; 아직 구조화되지 않음 · (Note: Thrust, stroke, and speed should be combined with actual usage, and the upper limit values of the three cannot be used together.) · 현재 기술 모델 · Basic parameters:; Source row: φ132 mm; Source column: Scalable length | ≤2000mm mm |
| 스크루 샤프트 원본 조건; 아직 구조화되지 않음 · (Note: The parameters of the ball screw are applicable to strokes ≤ 300mm. For strokes greater than 300mm, please consult our technical personnel.) · 현재 기술 모델 · Ball screw parameters; Source row: JFZ5010-8; Source column: Screw shaft | 40K12 |
| 세장비 원본 조건; 아직 구조화되지 않음 · (Note: The parameters of the ball screw are applicable to strokes ≤ 300mm. For strokes greater than 300mm, please consult our technical personnel.) · 현재 기술 모델 · Ball screw parameters; Source row: JFZ5010-8; Source column: Slenderness ratio | 1:50 |
| 동기 벨트 둘레 현재 기술 모델 · Synchronous wheel and synchronous belt:; Source row: 1:1; Source column: Synchronous belt circumference | 784 |
| 동기 벨트 폭 현재 기술 모델 · Synchronous wheel and synchronous belt:; Source row: 1:1; Source column: Synchronous belt width | 50mm mm |
| 동기 휠 속도비 (입력: 출력) 현재 기술 모델 · Optional configuration:; Source row: 10mm; Source column: Synchronous wheel speed ratio (input: output) | 1:1 |
| 동기 휠 속도비 (입력: 출력) 현재 기술 모델 · Optional configuration:; Source row: 10mm; Source column: Synchronous wheel speed ratio (input: output) | / |
| 동기 휠 속도비 (입력: 출력) 현재 기술 모델 · Optional configuration:; Source row: 10mm; Source column: Synchronous wheel speed ratio (input: output) | / |
| 유형 원본 조건; 아직 구조화되지 않음 · (Note: The parameters of the ball screw are applicable to strokes ≤ 300mm. For strokes greater than 300mm, please consult our technical personnel.) · 현재 기술 모델 · Ball screw parameters; Source row: JFZ5010-8; Source column: Type | Ball screw |
| 내경 원본 조건; 아직 구조화되지 않음 · (Note: Thrust, stroke, and speed should be combined with actual usage, and the upper limit values of the three cannot be used together.) · 현재 기술 모델 · Basic parameters:; Source row: φ132 mm; Source column: internal diameter | φ110mm mm |
| ΦA 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: External thread; Source column: ΦA | Φ110 |
| ΦA 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Internal thread; Source column: ΦA | Φ110 |
| ΦA 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Type I connector; Source column: ΦA | Φ110 |
| ΦA 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Fisheye bearing; Source column: ΦA | Φ110 |
| ΦA 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Y-joint; Source column: ΦA | Φ110 |
| ΦB 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: External thread; Source column: ΦB | Φ90 |
| ΦB 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Internal thread; Source column: ΦB | Φ90 |
| ΦB 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Type I connector; Source column: ΦB | Φ90 |
| ΦB 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Fisheye bearing; Source column: ΦB | Φ90 |
| ΦB 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Y-joint; Source column: ΦB | Φ90 |
| ΦC 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: External thread; Source column: ΦC | — |
| ΦC 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Internal thread; Source column: ΦC | — |
| ΦC 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Type I connector; Source column: ΦC | Φ40 |
| ΦC 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Fisheye bearing; Source column: ΦC | Φ50 |
| ΦC 현재 기술 모델 · Size Correspondence Table (Unit: mm); Source row: Y-joint; Source column: ΦC | Φ40 |
기본 매개변수
| 외경 | 내경 | 최대 허용 추력 | Scalable length | Maximum allowed speed Rotation angle of piston rod | 리미트 스위치 | |||||||||||||||||||||
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| φ132 mm | φ110mm mm | ≤130KN KN | ≤2000mm mm | ≤250 mm/s | ±0.3° ° | Proximity switch | ||||||||||||||||||||
원본에 기재된 옵션
| 볼스크루 리드 | 동기 휠 속도비 (입력: 출력) | 직접 장착 가능한 모터 사양 | 조합 가능한 감속기 | ||||||||||
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| 10mm mm | 1:1 | / | / | NO | 142A | 130A、180A | |||||||
| 20mm mm | |||||||||||||
볼 스크루 매개변수
| 볼스크루 모델 | 유형 | 직경 | 볼스크루 리드 | Ca (KN) | Coa (KN) | 볼스크루 강성 | 볼 직경 | 스크루 샤프트 | 세장비 | 위치결정 정밀도 | 정밀도 등급 | |||||||||||||||
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| JFZ5010-8 | Ball screw | 50 mm | 10mm mm | 104.1 KN | 251.2 KN | / | 7.144mm mm | 40K12 | 1:50 | C5/±0.01 | C7/±0.02 | ||||||||||||||
| SFU5010-8 | 104.1 KN | 251.2 KN | / | ||||||||||||||||||||||
| JFZ5020-7 | 20mm mm | 955 KN | 230.7 KN | / | |||||||||||||||||||||
베어링 매개변수
| 베어링 모델 | Cr (KN) | Cor (KN) | |||
|---|---|---|---|---|---|
| Deep groove ball 6009-ZZx2 | 19.9 KN | 14 KN | |||
| Flat thrust bearing 51212 | 73.5 KN | 179 KN |
타이밍 풀리 및 벨트
| 동기 풀리 속도비 | 구동 기어 사양 | 종동 기어 사양 | 구동 기어 잇수 | 종동 휠 잇수 | 동기 풀리 중심 거리 | 동기 벨트 둘레 | 동기 벨트 폭 | ||||||||
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| 1:1 | 14M65T77 T | 14M65T77 T | 28 | 28 | 196mm mm | 784 | 50mm mm | ||||||||
치수 대응 표 (mm)
| 부하 연결 방식 | ΦA | ΦB | ΦC | C | D | E | F | H | G | M | ||||||||||||
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| External thread | Φ110 | Φ90 | — | 70 | 120 | 10 | 14 | — | — | M50x2 | ||||||||||||
| Internal thread | Φ110 | Φ90 | — | 45 | 50 | 10 | — | — | — | M30x1.5 | ||||||||||||
| Type I connector | Φ110 | Φ90 | Φ40 | — | 245 | 10 | 40 | 85 | — | — | ||||||||||||
| Fisheye bearing | Φ110 | Φ90 | Φ50 | — | 165 | 10 | 60 | — | — | — | ||||||||||||
| Y-joint | Φ110 | Φ90 | Φ40 | — | 245 | 10 | 40.3 | 86 | 85 | — | ||||||||||||
HTROBOT에 상담
- Miniature Pneumatic Cylinder Motor Servo Electric Actuator Valve Underfloor Linear IP65 12v 24v Electric High Speed ↗
Alibaba 시리즈 상품 · EDA140
시리즈 참고 상품입니다. 현재 구성을 판매자에게 확인하세요.
- 이메일emmy@htrobot.com
- 전화+86 152 0225 5004
- Alibaba 스토어Alibaba 스토어 방문